Associate Professor · Electrical and Computer Engineering
Carnegie Mellon University
Yorie Nakahira
Control and learning for autonomous systems that stay safe, robust, and adaptable over a lifetime of operation.
About
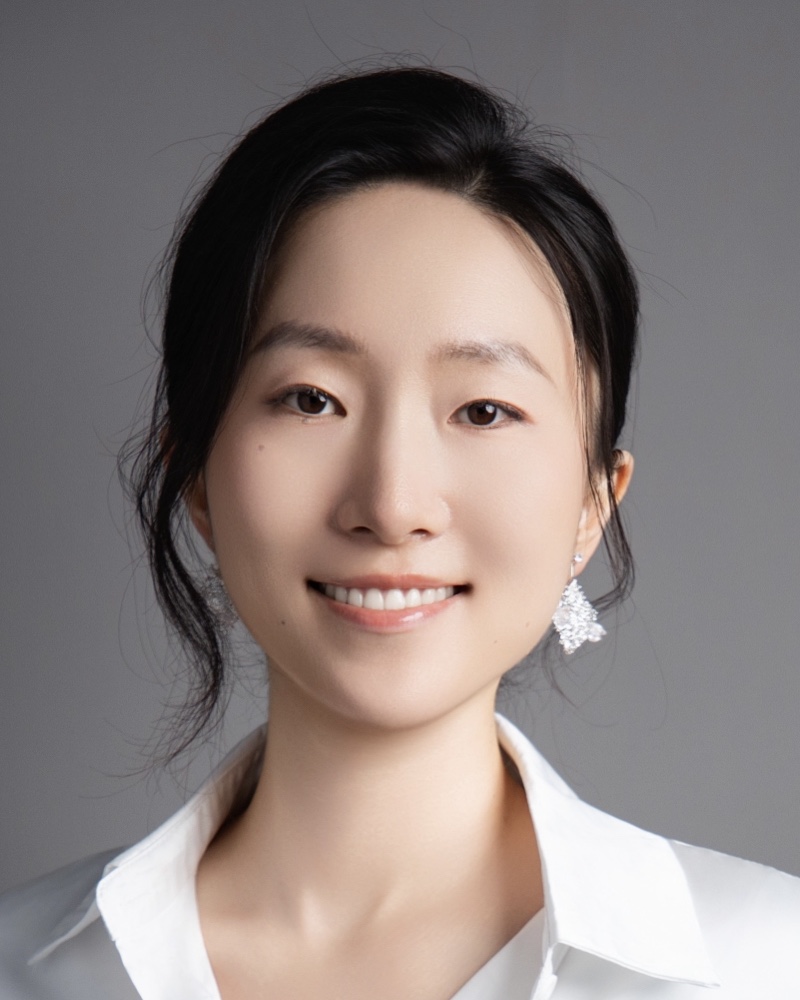
Yorie Nakahira is an Associate Professor of Electrical and Computer Engineering at Carnegie Mellon University, with courtesy appointments in the Neuroscience Institute and the Robotics Institute. She also serves as a Project Researcher at the Research and Development Center for Large Language Models at Japan's National Institute of Informatics.
Her research develops control and learning techniques that give autonomous systems lifelong assurance of safety, robustness, efficiency, and adaptability. Her group works on robust and safe control, risk quantification, learning under uncertainty, and language-guided control, with applications ranging from autonomous vehicles and robots to human sensorimotor control and poverty-alleviation policy design.
She received her Ph.D. in Control and Dynamical Systems from the California Institute of Technology in 2019, advised by John C. Doyle, and her B.E. in Control and Systems Engineering from Tokyo Institute of Technology in 2012. She is a recipient of the NSF CAREER Award and the Japan Science and Technology Agency's Young Investigator Award, and was selected for the National Academy of Engineering's U.S. Frontiers of Engineering Symposium.
Research
Research at a glance
Robust and safe control
Probabilistic safety certificates that keep long-term risk within tolerance, even with latent variables, occlusions, and limited communication.
Read more 02Risk quantification and probabilistic reachability
Physics-informed learning that infers long-term risk from short, sparse data by exploiting the PDE structure of risk probabilities.
Read more 03Neural networks for uncertain and non-stationary systems
Analytic moment propagation and Bayesian fine-tuning that make deep learning reliable and fast to adapt in physical systems.
Read more 04Intelligent control and human–machine interaction
Resilient control, learning-based stabilization, predictive control, and interaction-aware decision making for systems that share their environment with people.
Read more 05Language-guided and context-aware control
Large language models supplying context, preferences, and risk awareness to controllers with formal safety guarantees.
Read more 06Physical AI and humanoid robots
Next-generation vision-language-action models deployed on humanoid robots, with ultra-efficient fine-tuning, in collaboration with Fujitsu Research's Physical AI initiative.
Read more 07Insights from biological systems
Diversity-enabled sweet spots that explain how nervous systems achieve fast, accurate control with slow, noisy components.
Read more 08AI for physical AI research
Sequential fine-tuning and uncertainty awareness so that robots keep learning safely, toward a machine that builds autonomous systems.
Read moreHighlights
News
- 2026Fujitsu and Carnegie Mellon University launch the Fujitsu–Carnegie Mellon Physical AI Research Center; our group develops and deploys vision-language-action models on humanoid robots as part of the initiative. Press release.
- 2026Young Investigator Award (PRESTO), Japan Science and Technology Agency, for developing “a machine that builds autonomous systems” through LLM-guided control and learning. CMU story.
- 2026Paper accepted to ICML 2026: Training-Free Guided Diffusion for Planning: A Unified Framework via Doob's h-Transform with Safety Guarantees. A training-free way to steer pretrained diffusion planners toward safe plans through Doob's h-transform, with safety guarantees.
- 2026Paper accepted to ICLR 2026: Polynomial Convergence of Riemannian Diffusion Models. Polynomial convergence guarantees for diffusion models whose data lie on a manifold, removing the exponentially small step sizes required by earlier analyses.
- 2026Paper accepted to L4DC 2026: Online Adaptive Probabilistic Safety Certificate with Language Guidance. A language-guided adaptive safety certificate that guarantees long-term safety under environmental uncertainty while accommodating user preferences expressed in natural language.
- 2026Paper accepted to ACC 2026: Context-Aware LLM-Based Safe Control Against Latent Risks. Combines large language models, numerical optimization, and model predictive control to decompose complex tasks into context-aware subtasks that stay safe against latent risks.
- 2025NSF CAREER Award, Energy, Power, Control, and Networks program, for safety, human (mis)alignment, and interaction-awareness in control.
- 2025Appointed Project Researcher at the Research and Development Center for Large Language Models, National Institute of Informatics, Japan.
- 2025Young Investigator Award (BOOST), Japan Science and Technology Agency.
- 2025Paper accepted to NeurIPS 2025: Stabilizing Linear Systems under Partial Observability: Sample Complexity and Fundamental Limits. Sample-complexity bounds and fundamental limits for learning to stabilize unknown, partially observable linear systems.
- 2025Paper accepted to ICML 2025: Safety Certificate Against Latent Variables with Partially Unidentifiable Dynamics. Probabilistic safety certificates that remain valid when latent variables make dynamics partially unidentifiable or shift the observed statistics.
- 2025Paper accepted to UAI 2025: Sample Complexity of Stabilizing LTI Systems on a Single Trajectory under Stochastic Noise. Learns to stabilize an unknown noisy linear system on a single trajectory by exploring only its unstable subspace, avoiding exponential state blow-up.
- 2025Paper accepted to CDC 2025: Kalman Bayesian Transformer. Frames sequential fine-tuning of transformers as Bayesian posterior inference, enabling stable, uncertainty-aware adaptation from small amounts of new data.
- 2025Paper accepted to CDC 2025: Neural Spline Operators for Risk Quantification in Stochastic Systems. Neural operators built on B-spline representations that map varying system dynamics to long-term risk probabilities.
- 2025Paper accepted to ACC 2025: Fast Bandit-Based Policy Adaptation in Diverse Environments. Bandit-based meta-reinforcement learning that adapts policies quickly across diverse environments.
- 2025Paper accepted to Journal of Machine Learning Research: Physics-Informed Deep B-Spline Networks for Dynamical Systems. Learns families of PDE solutions through B-spline control points, enforcing initial and boundary conditions by construction with theoretical guarantees.
- 2025Paper accepted to IEEE Transactions on Automatic Control: Myopically Verifiable Probabilistic Certificates for Safe Control and Learning. Introduces probabilistic invariance to derive myopic control conditions that certify long-term safety in stochastic systems and support safe learning.
- 2025Paper accepted to IEEE Transactions on Automatic Control: Generalizable Physics-Informed Learning for Stochastic Safety-Critical Systems. Characterizes long-term risk probabilities by partial differential equations and uses physics-informed learning to infer them from short-term samples with few risk events.
- 2025Paper accepted to IEEE Transactions on Control of Network Systems: Probabilistic Safety Certificate for Multi-Agent Safe Control and Learning. Probabilistic safety certificates for multi-agent safe control and learning without centralized communication.
- 2025Paper accepted to Neural Computation: Diversity Deconstrains Component Limitations in Sensorimotor Control. Explains how diversity among neurons lets sensorimotor systems achieve fast and accurate control despite slow, noisy components, accounting for Fitts' law.
- 2024Keynote speaker, IEEE/SICE International Symposium on System Integration.
- 2023Selected for the U.S. Frontiers of Engineering Symposium of the National Academy of Engineering.
- 2023Keynote speaker, AI Engineering & Innovation Summit, CMU Thailand.
- 2022Keynote speaker, joint symposium of the European Research Consortium for Informatics and Mathematics and the Japan Science and Technology Agency.
- 2021Young Investigator Award (PRESTO, Future IoT program), Japan Science and Technology Agency.
- 2020Featured in the “People in Control” column of IEEE Control Systems Magazine. Joined the ECE faculty at Carnegie Mellon.
- 2018Selected for the Rising Stars Women in Engineering Workshop, Asian Deans’ Forum.
- 2011Selected by the Japan Prize Foundation as one of two Japanese student representatives at the Nobel Prize ceremony.
Contact
Get in touch
Prospective students and postdocs interested in my group, please check out Join the research group.
- yorie@cmu.edu
- Office
- Roberts Engineering Hall 338
- Phone
- 412-268-1429
- Department of Electrical and Computer Engineering
Carnegie Mellon University
5000 Forbes Avenue, Pittsburgh, PA 15213